Tutorials#
Worked examples, from a single LQR solve to differentiating through iLQR. Each notebook explains
the problem, solves it, checks the result and ends with a How to adapt section. The
repository’s examples/ folder has standalone script versions.
Linear Quadratic Regulator (LQR)#
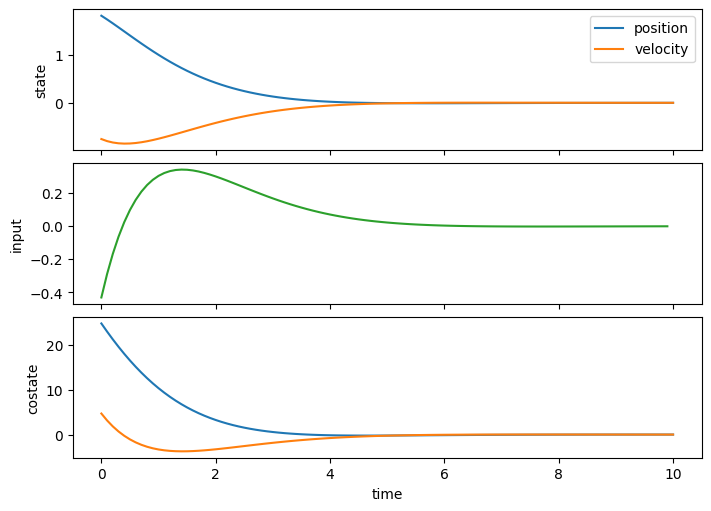
LQR: bringing a double integrator to rest
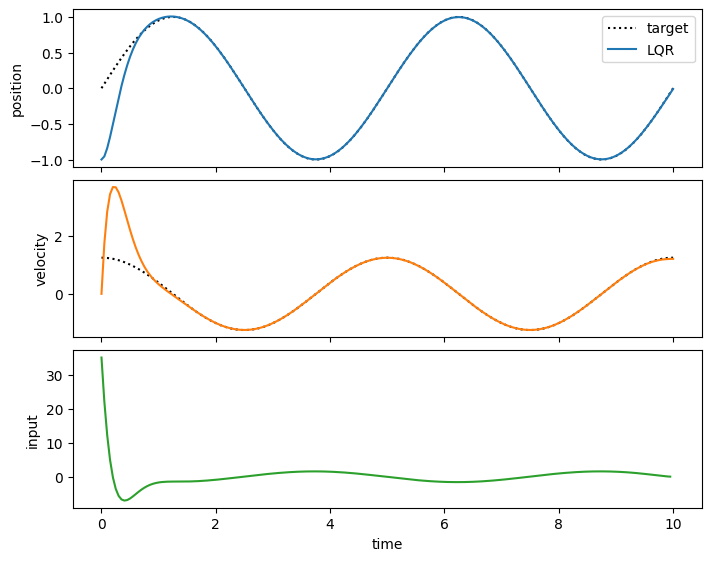
LQR tracking of a reference trajectory
Iterative LQR (iLQR)#
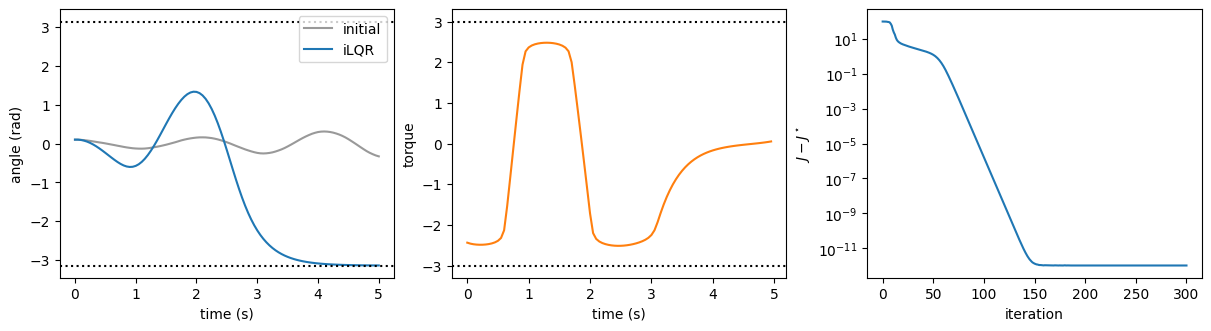
iLQR: pendulum swing-up
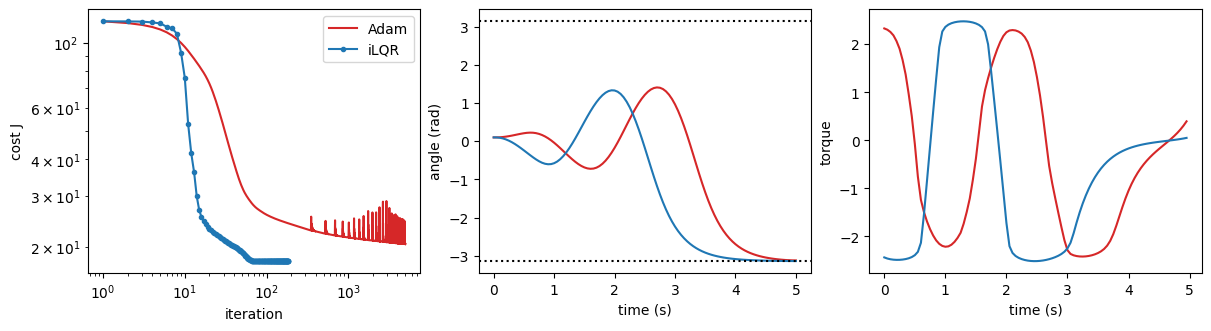
iLQR compared with gradient descent
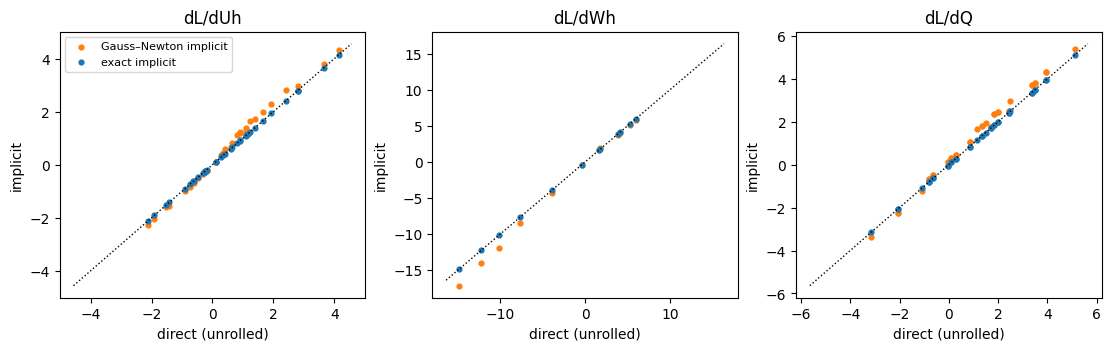
Implicit gradients through iLQR
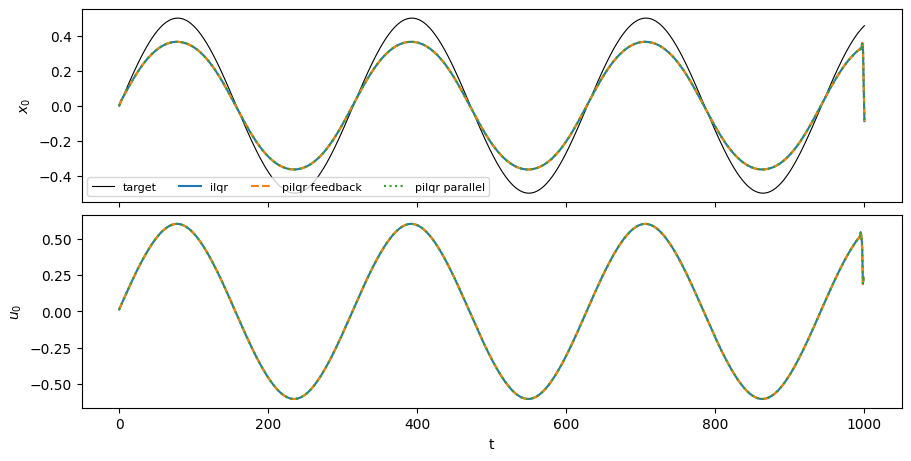
Parallel (associative-scan) solvers
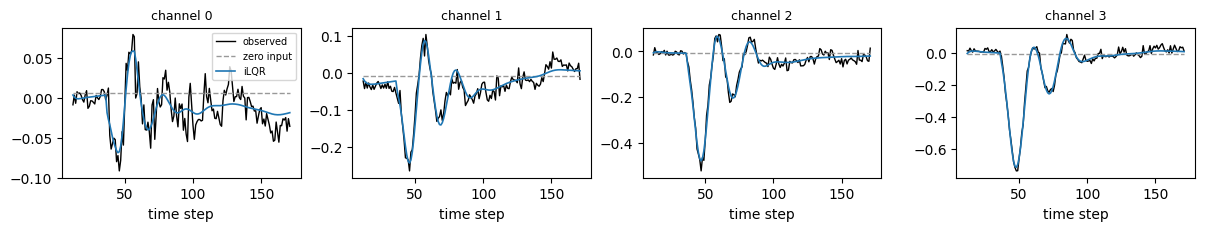
iLQR inference: reconstructing a zebrafish tail bout
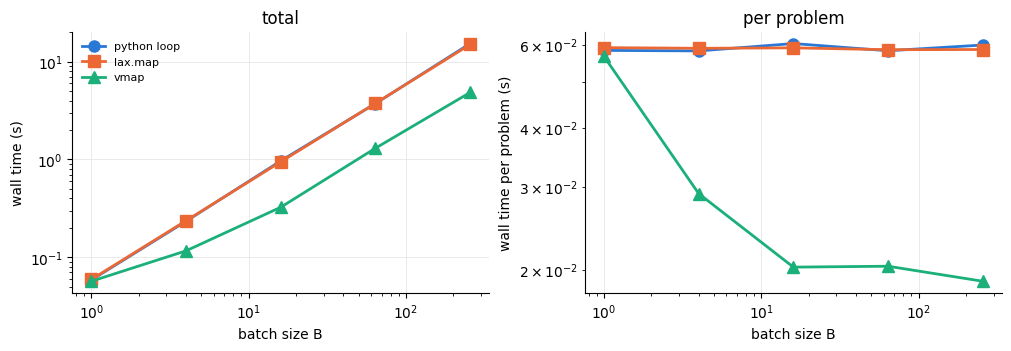
Batched iLQR: many tracking problems at once