Design Principles#
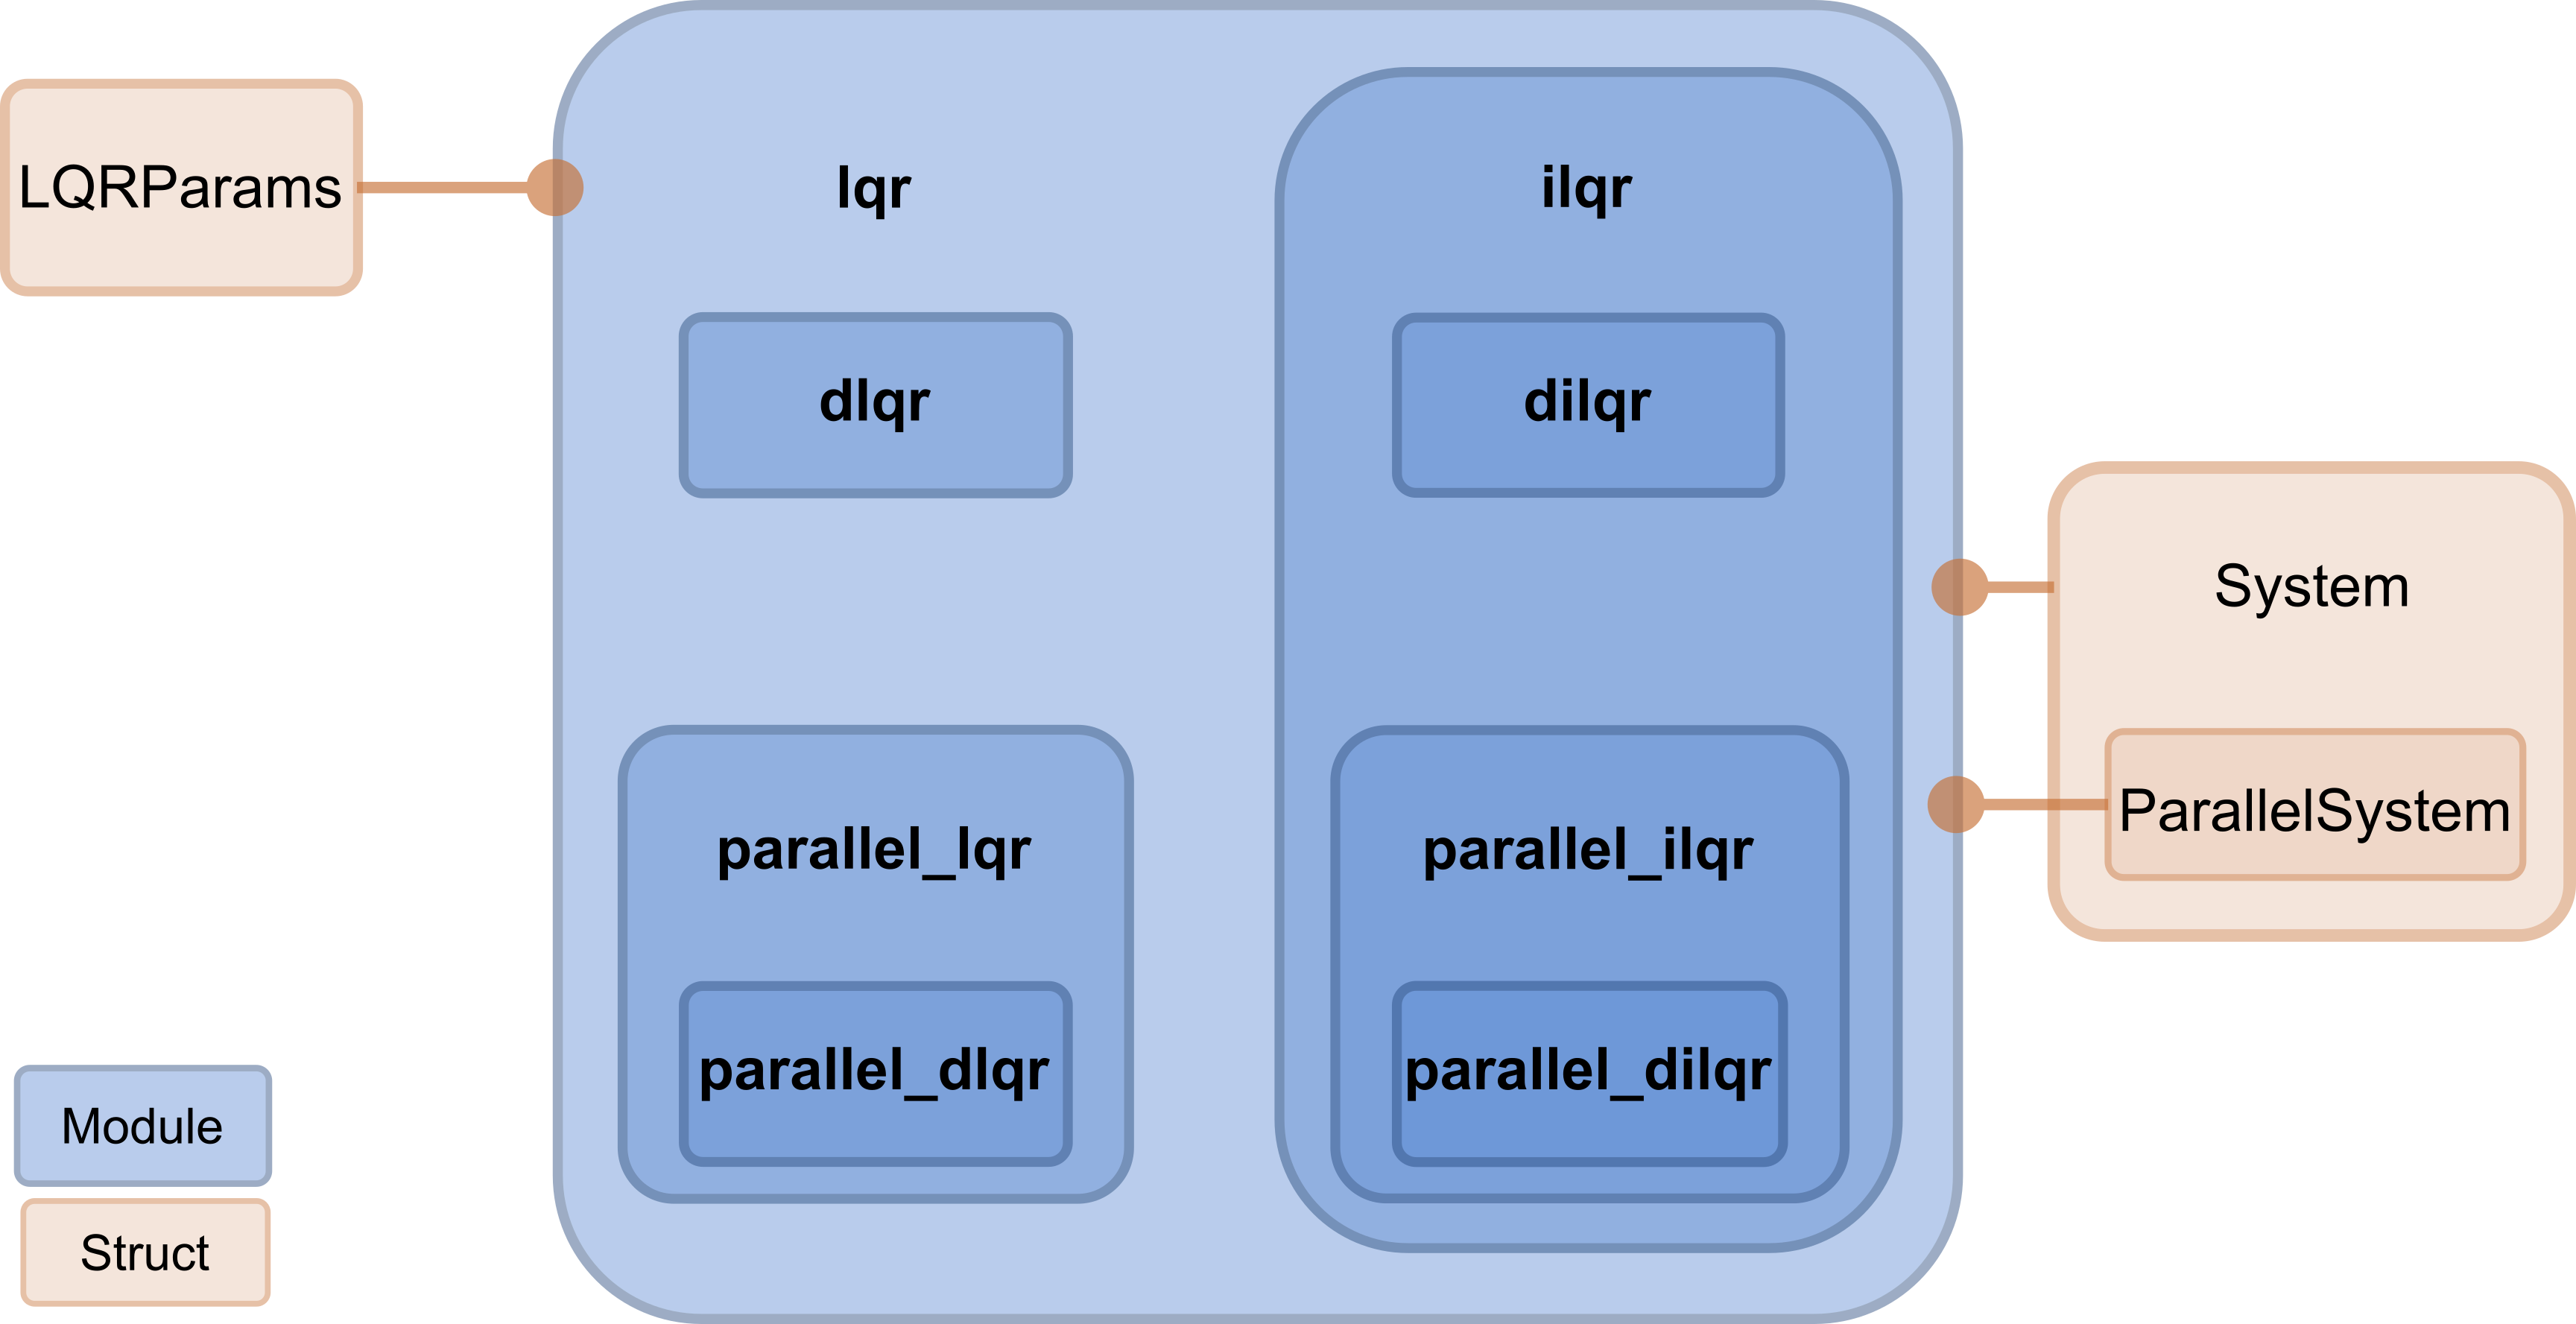
Each problem class, LQR or iLQR, has a sequential and a parallel solver. Each solver also has a differentiable wrapper with implicit gradients.
Solver type |
Module |
Entry point |
Suited to |
Arguments |
|---|---|---|---|---|
Sequential |
|
CPU |
|
|
|
CPU |
|
||
Parallel |
|
GPU |
|
|
|
GPU |
|
||
Differentiable |
|
|
CPU |
|
|
CPU |
|
||
|
GPU |
|
||
|
GPU |
|
The layout of the modules are hierarchically structure outlined in the schematic below: